PhotonIcs and Electromagnetics Research Symposium,
also known as Progress In Electromagnetics Research Symposium
PIERS Proceedings
Published: 2015-08-28
A Real Time 3D Multi Target Data Fusion for Multistatic Radar Network Tracking
By
Proceedings of 2015 Photonics & Electromagnetics Research Symposium, Prague, July 6 - 9,Page(s)44-49
Abstract
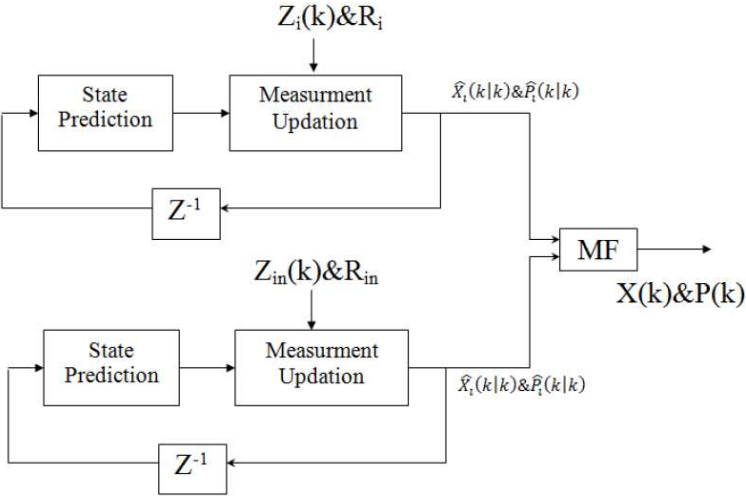
The paper is devoted to propose a data fusion algorithms into multistatic radar network to improve its tracking capability. The proposed data fusion algorithm is based on using common measurement architecture gives state estimates with relatively low and medium uncertainty followed by cumulative measurement fusion (CMF) or cumulative state vector fusion (CSVF) algorithm which is very simple, easy to implement and can be used in real time. Extended Kalman Filter (EKF) is used as a non-linear tracking and predictor algorithm. The system is simulated using Matlab program to compare the performance of the estimation routines of both fusion algorithms and the targets scenario is simulated using Monte Carlo simulation. Simulation results have shown that these cumulative fusion algorithms improve the multistatic radar network tracking capability and produce a significant reduction in the root sum square error (RSSE), absolute error, and root sum square variance (RSSV) than achieved from monostatic radar.
Citation
Tarek Reda Abd-ElShahid, El-Sayed Abdoul Moaty El-Badawy, and Alaa El-Din Sayed Hafez, "A Real Time 3D Multi Target Data Fusion for Multistatic Radar Network Tracking," Proceedings of 2015 Photonics & Electromagnetics Research Symposium, Prague, July 6 - 9,Page(s)44-49
References